01
TeleDexter: Towards Human-level Dexterous Teleoperation
Puhao Li*,
Zeyuan Chen*,
Yingying Wu*,
Pengkun Wei,
Yuyang Li,
Tianyu Wang,
Jiaxiao Shi,
Mingrui Yu,
Baoxiong Jia,
Song-Chun Zhu,
Tengyu Liu,
Siyuan Huang
[CoRL 2026] Conference on Robot Learning 2026
arXiv / website
[CoRL 2026] Conference on Robot Learning 2026
arXiv / website
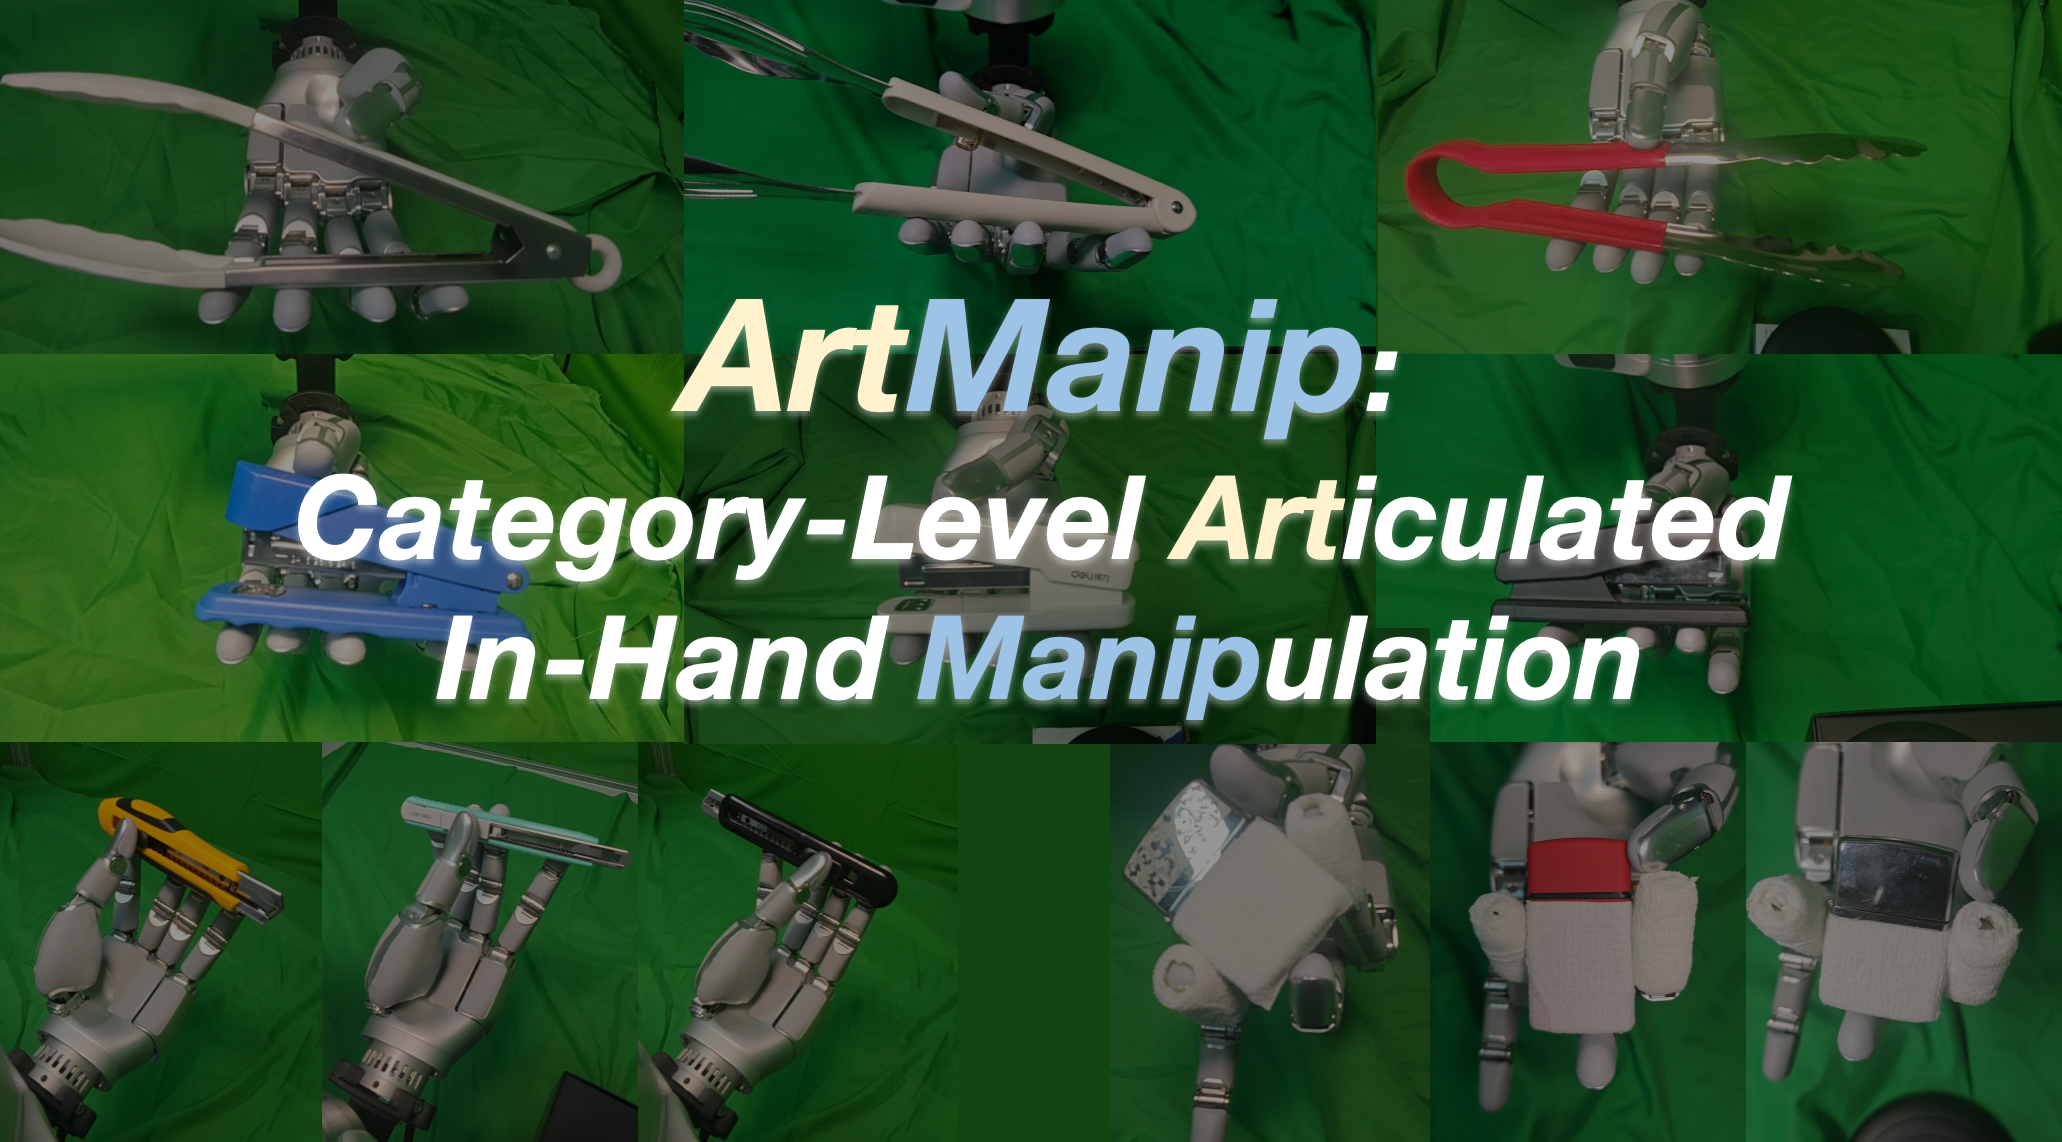
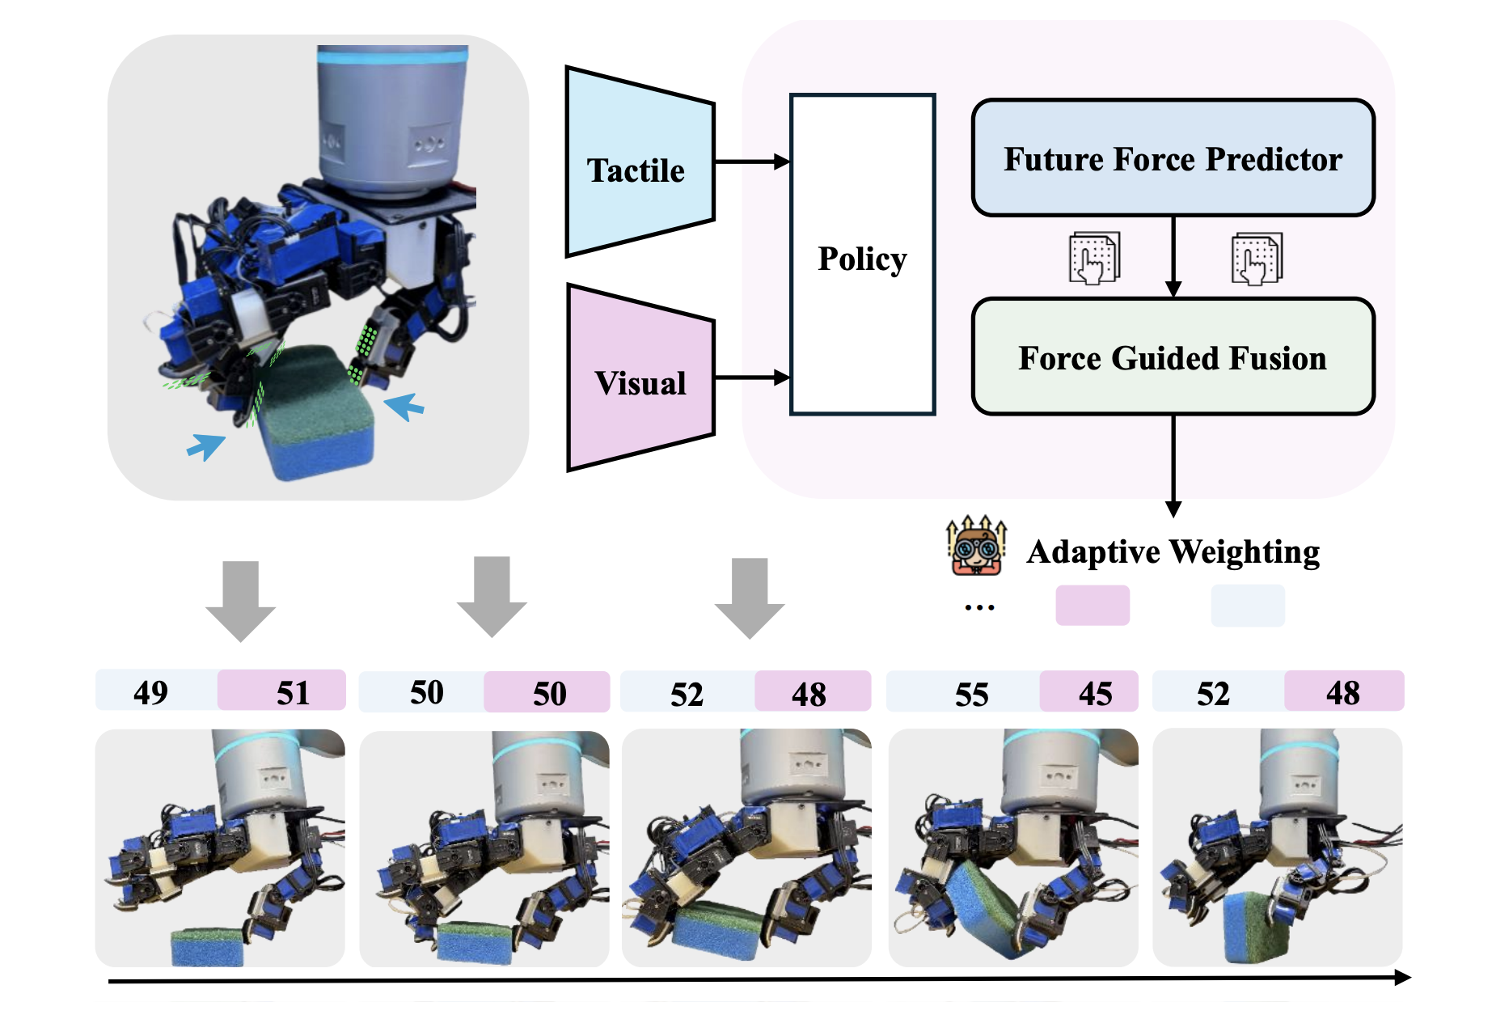
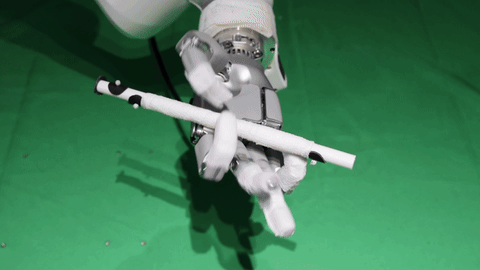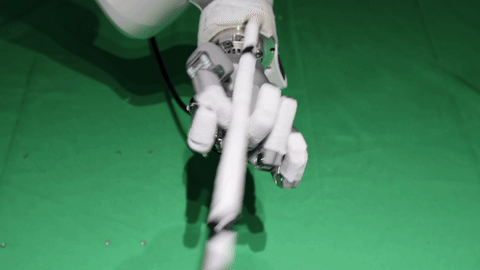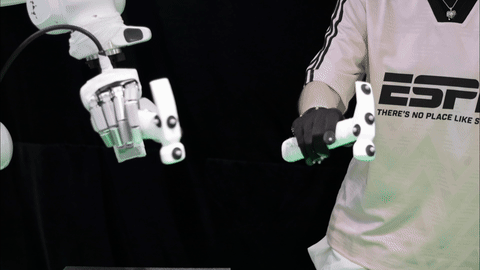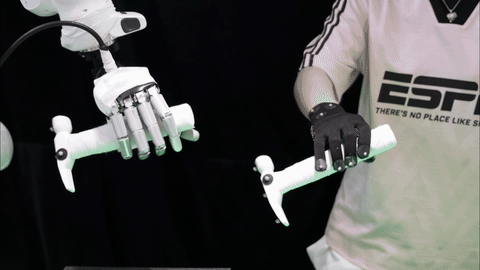
We introduce TeleDexter, a hand-object co-tracking controller that maps operator intent into learned low-level contact execution for dexterous teleoperation. The system transfers zero-shot to real robots and enables challenging in-hand reorientation and long-horizon tool-use tasks.